
Multibeam echosounder
Tilt Adapter Lever Arm
Calculate the resultant port/starboard and up/down lever arms after rotating a sonar on a tilt adapter.
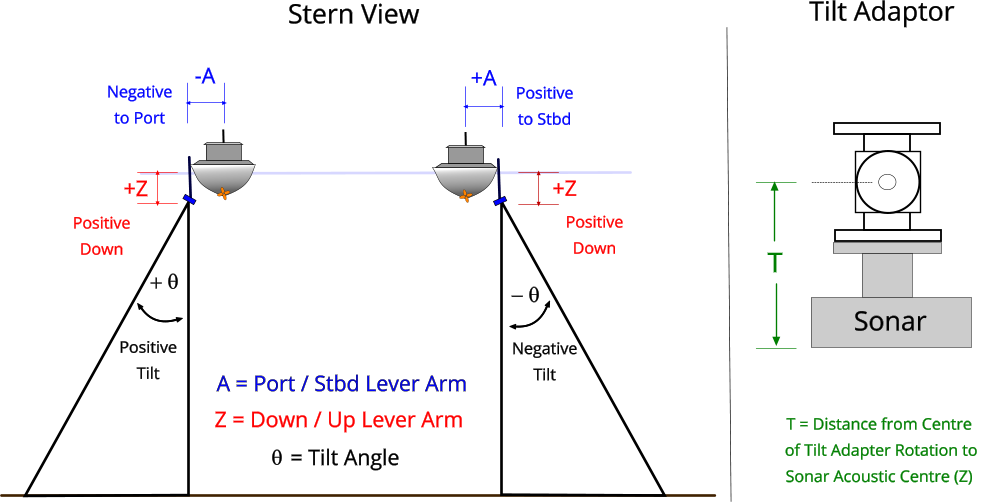
Variables
| A | Sonar Port/Starboard lever arm (starboard = positive) |
| Z | Sonar Up/Down lever arm (down = positive) |
| T | Vertical distance from tilt adapter centre to sonar acoustic centre |
| Θ | Tilt angle in degrees (clockwise = positive) |
| Y′ | New Port/Starboard lever arm = A + T·sin(−Θ) |
| Z′ | New Up/Down lever arm = Z − T·(1 − cos(Θ)) |
Sign convention: Starboard and downward offsets are positive. Clockwise rotation (when viewed from aft) is a positive tilt angle. Rotating the sonar upward toward starboard is a negative angle — a sonar mounted on the starboard side and rotated up uses a negative tilt angle.
Sonar Parameters
Range: −500 – 500 | Unitless
Range: −500 – 500 | Unitless
Tilt Adapter Parameters
Range: 0.01 – 50 | Unitless
Range: −175 – 175
Rotating the sonar up to starboard is a negative angle. A sonar mounted on the starboard side and rotated up uses a negative tilt angle.
Resultant Lever Arm
New Port/Starboard Lever Arm — Y′ (starboard = positive)
—
New Up/Down Lever Arm — Z′ (down = positive)
—
These results are informational only. Verify all lever arm values against physical measurements before use in sonar processing software. MosaicHydro accepts no liability for decisions made based on this tool.